About the project
Two robots for the floating solar farm at Sirindhorn Dam, built for the Electricity Generating Authority of Thailand (EGAT). One cleans the solar panels, and the other transports solar panels across the site.
The robots have to work across a large, open site on the water, with reliable docking and no one driving them.
The work covers the robot's movement, docking, and autonomous navigation. ROS 2 connects to the embedded controller through micro-ROS, which runs PID wheel-speed control, and Nav2 navigates using SLAM with a 2D LiDAR and RTK GNSS.
Process
Map the site
SLAM with a 2D LiDAR builds the map, and RTK GNSS anchors it outdoors.
Connect the embedded controller
A micro-ROS bridge links ROS 2 to the embedded controller, which runs PID wheel-speed control.
Navigate and dock
Nav2 drives the robot autonomously, and dedicated movement and docking systems handle the panel transport.
Figures
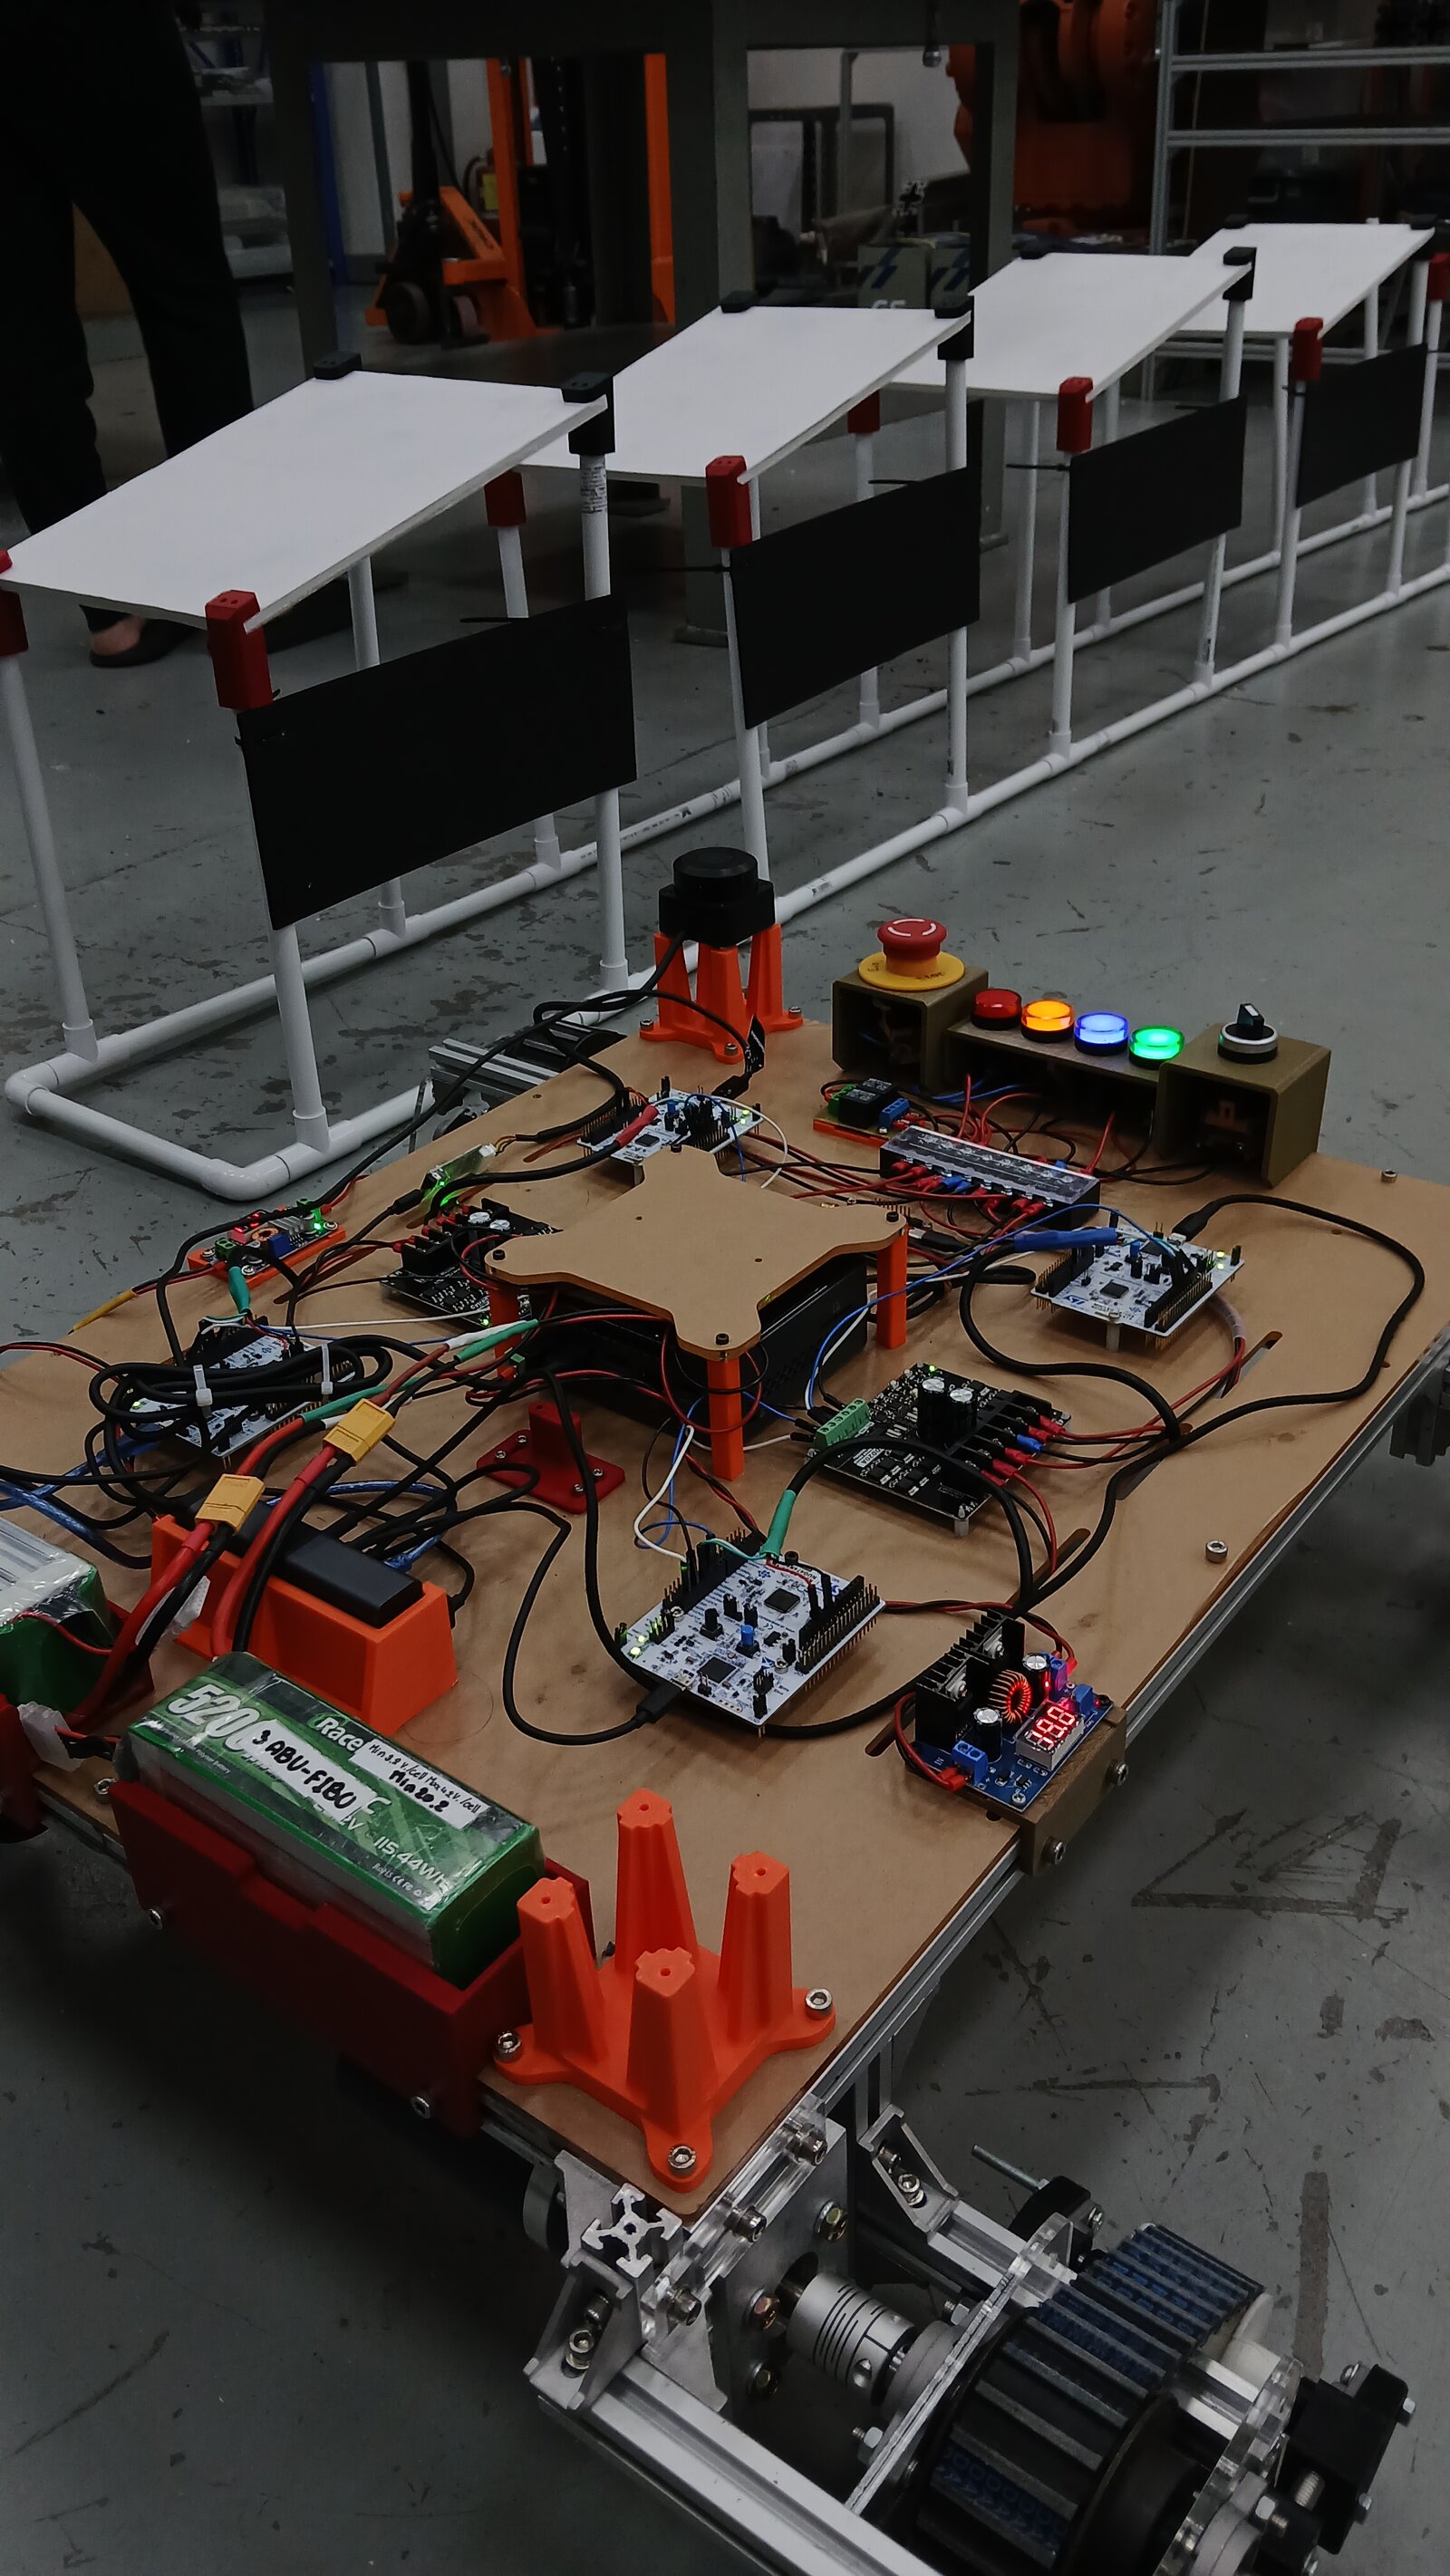
System
| Client | Electricity Generating Authority of Thailand (EGAT) |
|---|---|
| Site | Sirindhorn Dam floating solar farm |
| Software | ROS 2, Nav2, micro-ROS |
| Sensors | 2D LiDAR, RTK GNSS |
| Role | Research Assistant |